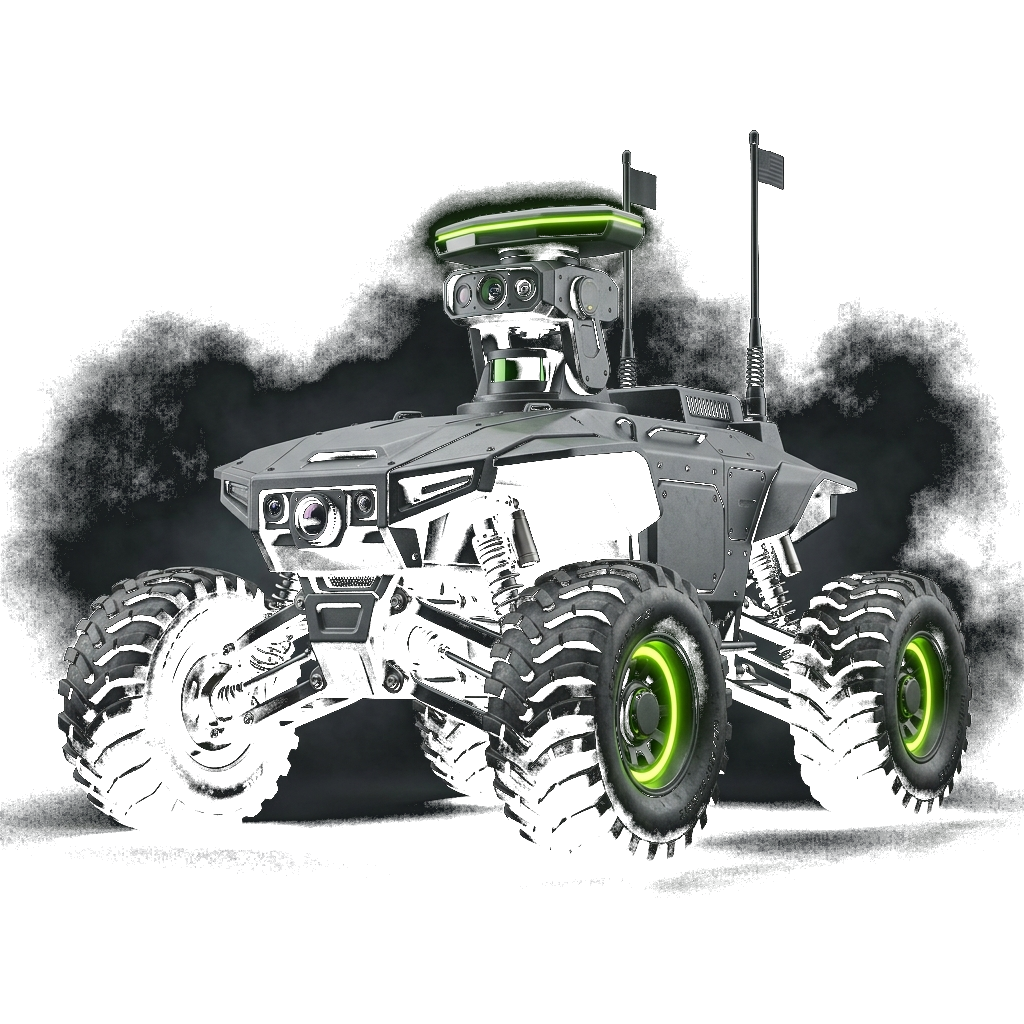
Chetas UGV
Smartphone-powered autonomous ground rover. Bypasses complex external sensors and uses onboard mobile NPU processors for local perception, mapping, and path planning.
Edge Autonomy & Sensing
By running concurrent computer vision logic directly on standard processing silicon, we eliminate fragile external lidar hardware.
360° Optical Stitching
Feeds concurrent front and rear camera frames into a local stitching model, producing complete side-by-side terrain overlays without auxiliary hardware payload weight.
Waypoint Autonomy
Local GPS positioning logs feed continuous target bearings into heading control loops, executing complex preset grid inspections and patrol routes autonomously.
Secure Local Link
Protects edge operations. Remote waypoints coordination registers and device command overrides are cryptographically secured using signature keys.
Platform Layout.
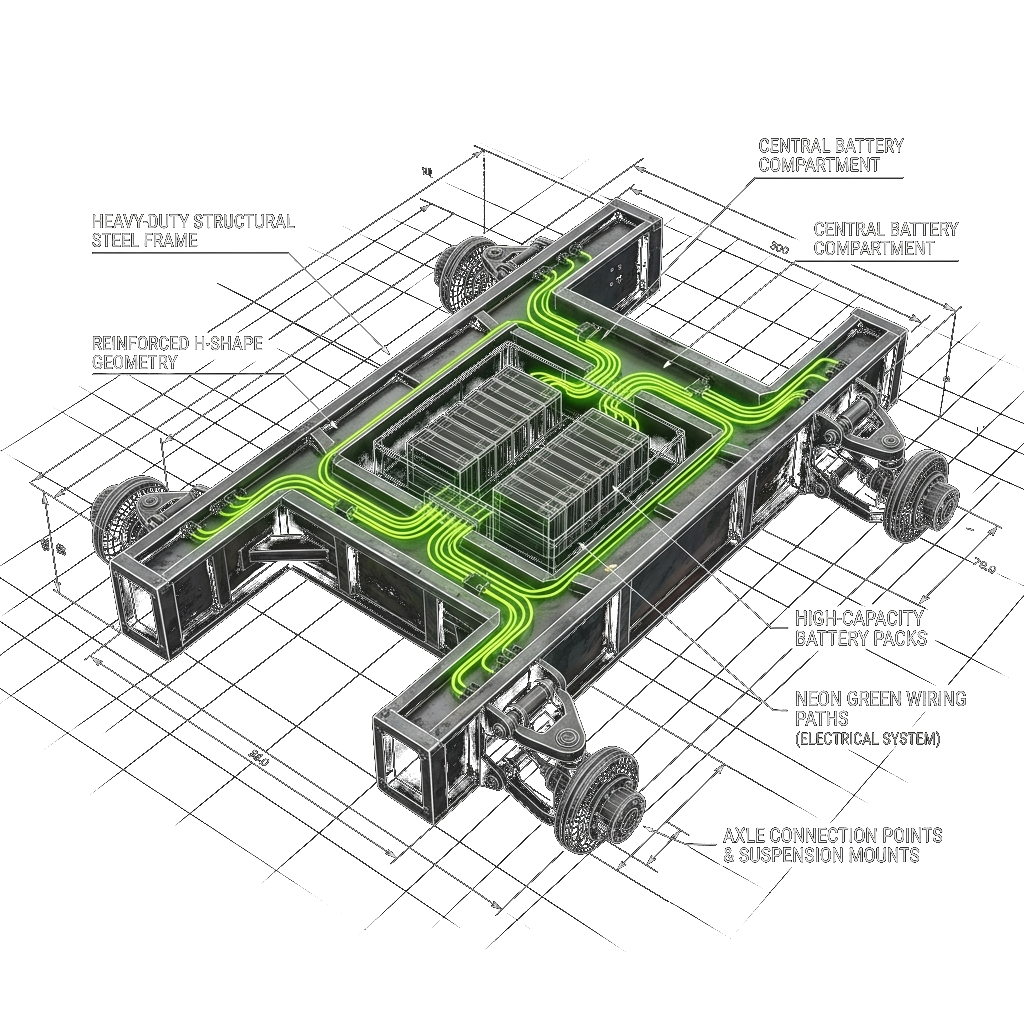
Rugged H-Chassis Architecture
The robot frame features a structural carbon-reinforced H-shape chassis. The center compartment is extended to house high-density lithium power packs, distributing the payload mass evenly and keeping the physical center of gravity extremely close to the terrain plane.
Request Platform Schematics
Complete CAD drawings, weight parameters, and local link manuals are available under NDA.